Hardware design: robot arm, Teachbot, grippers and cells
TOS Robotics designs its own hardware. We design the TOS Robot arm, the Teachbot, the grippers and complete cells for production lines.
- Robot arm
- The TOS Robot
- Teaching device
- The Teachbot
- Grippers
- Designed with the cell
- Cells
- For production lines
What we design
Robot arm
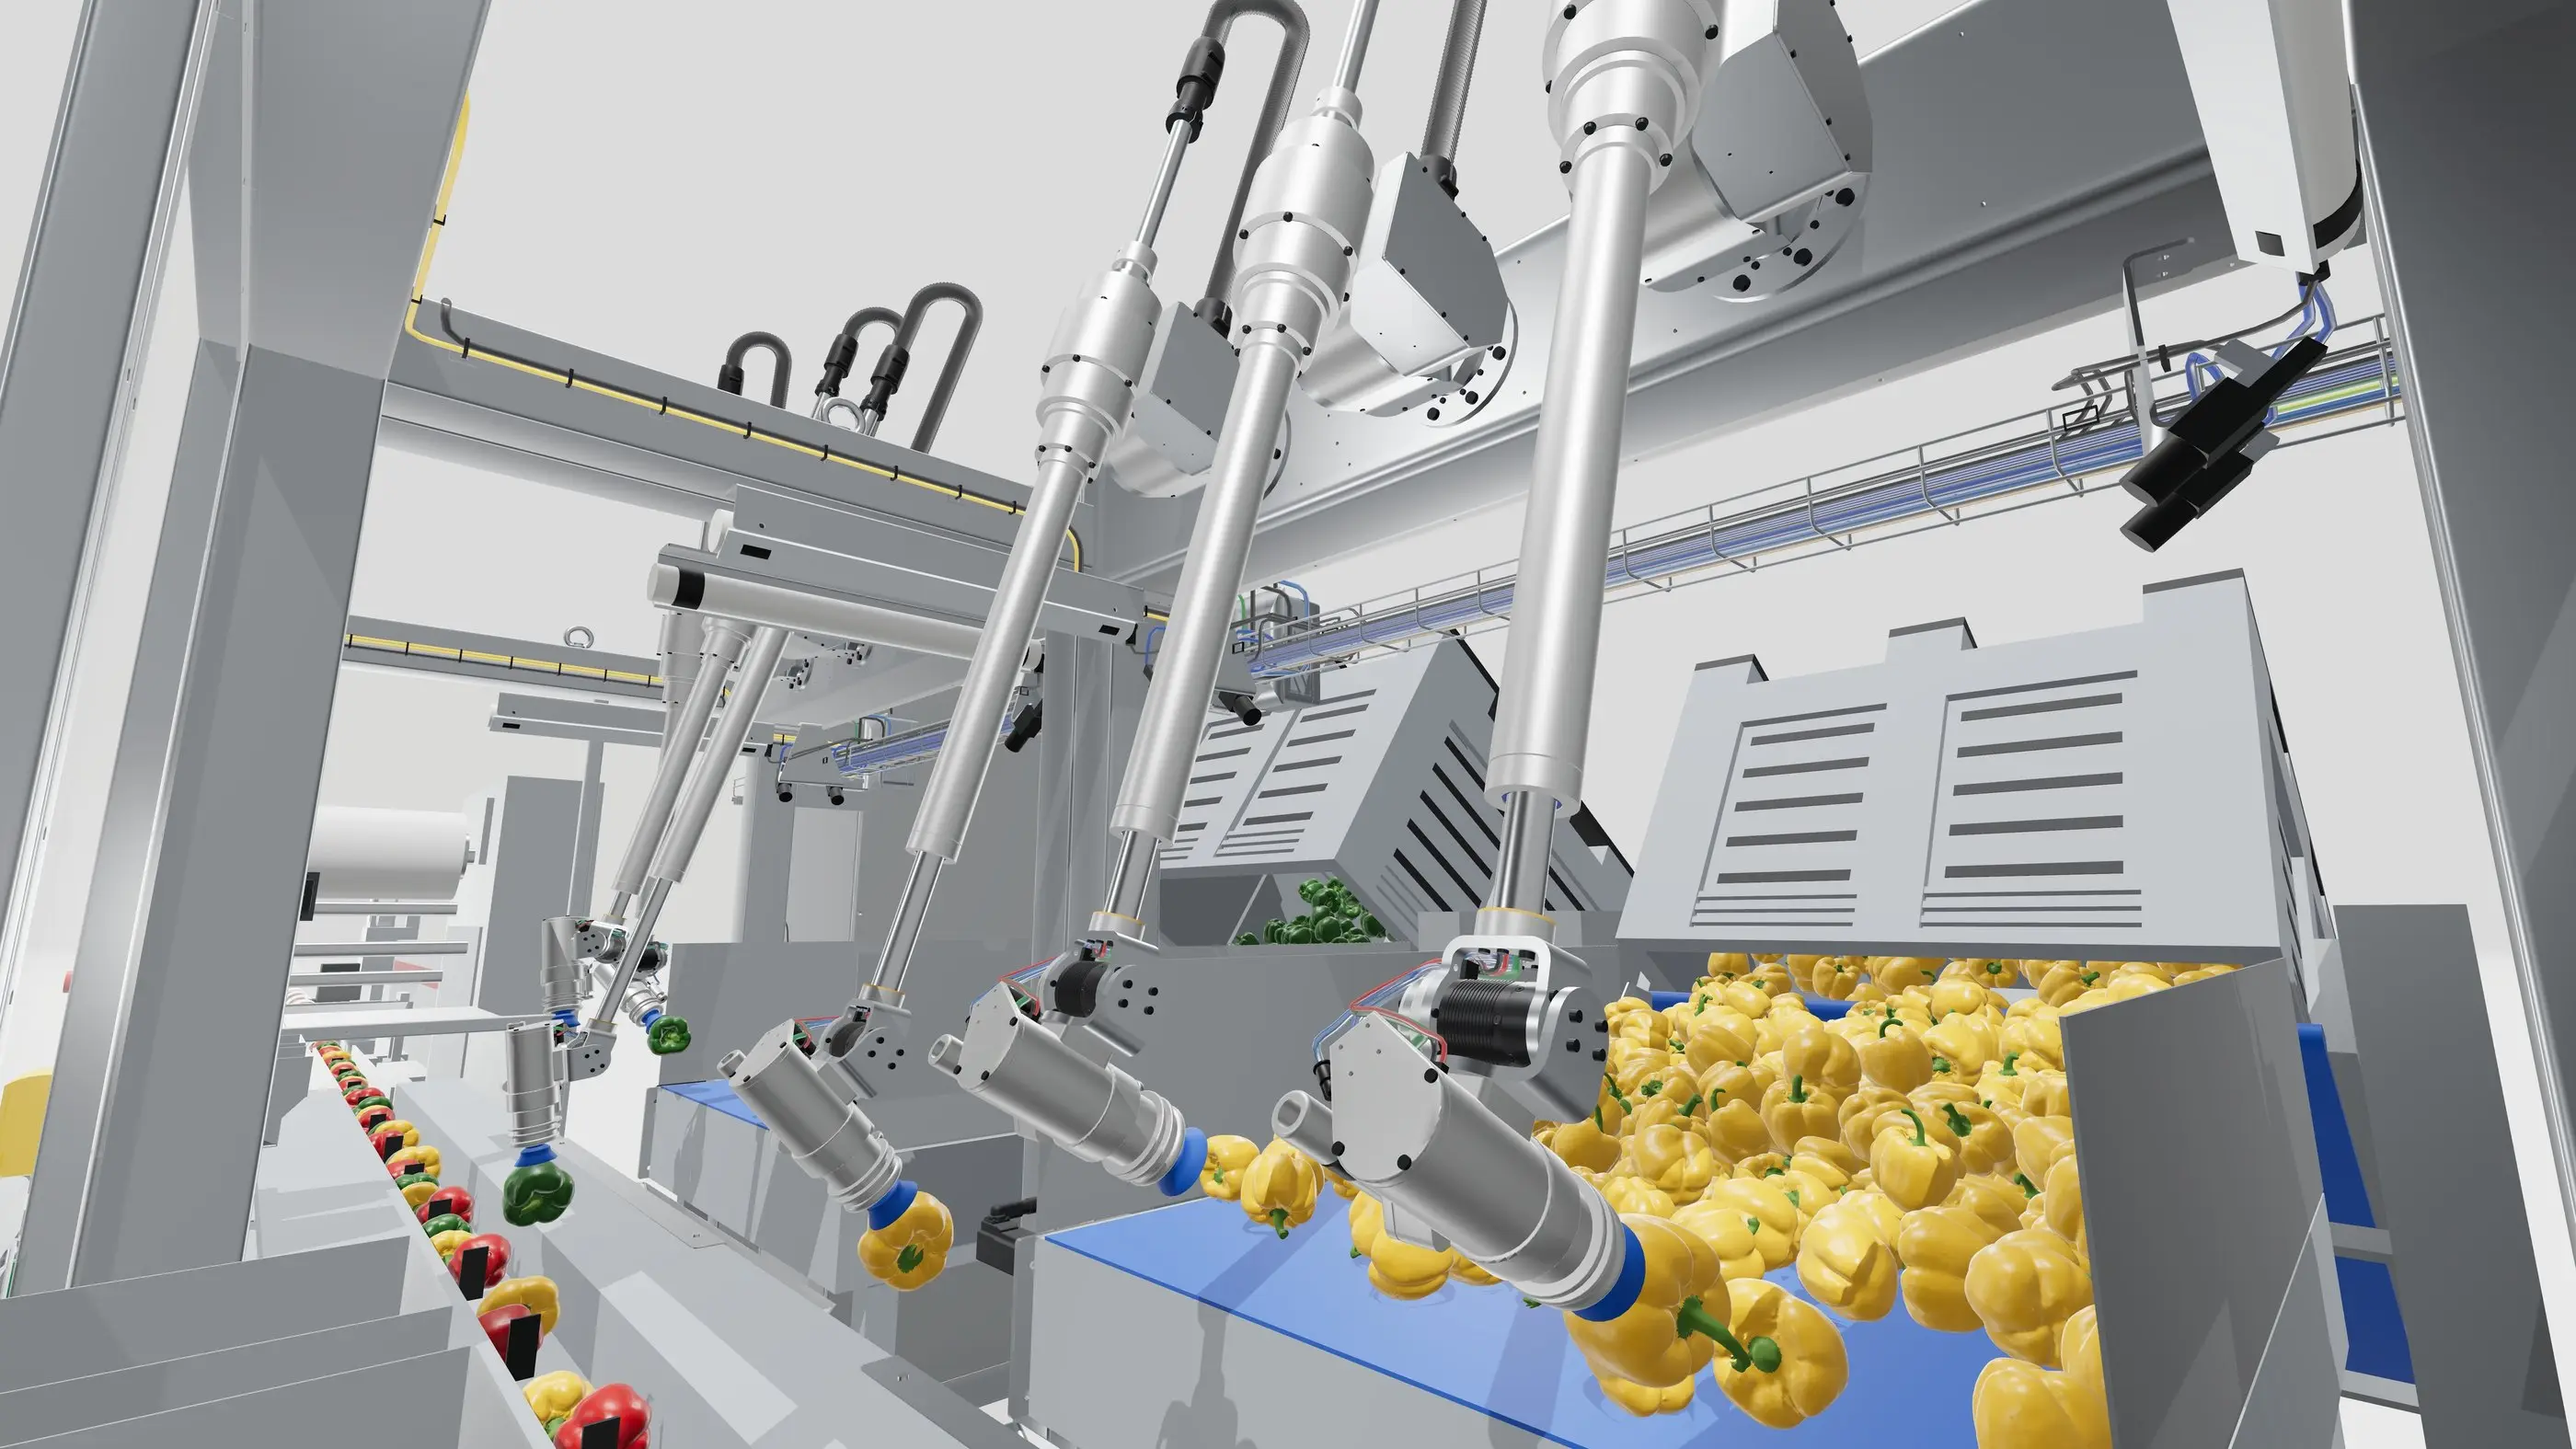
The TOS Robot hangs three arms on one beam above the belt, with the heavy drives at the beam.
Teaching device
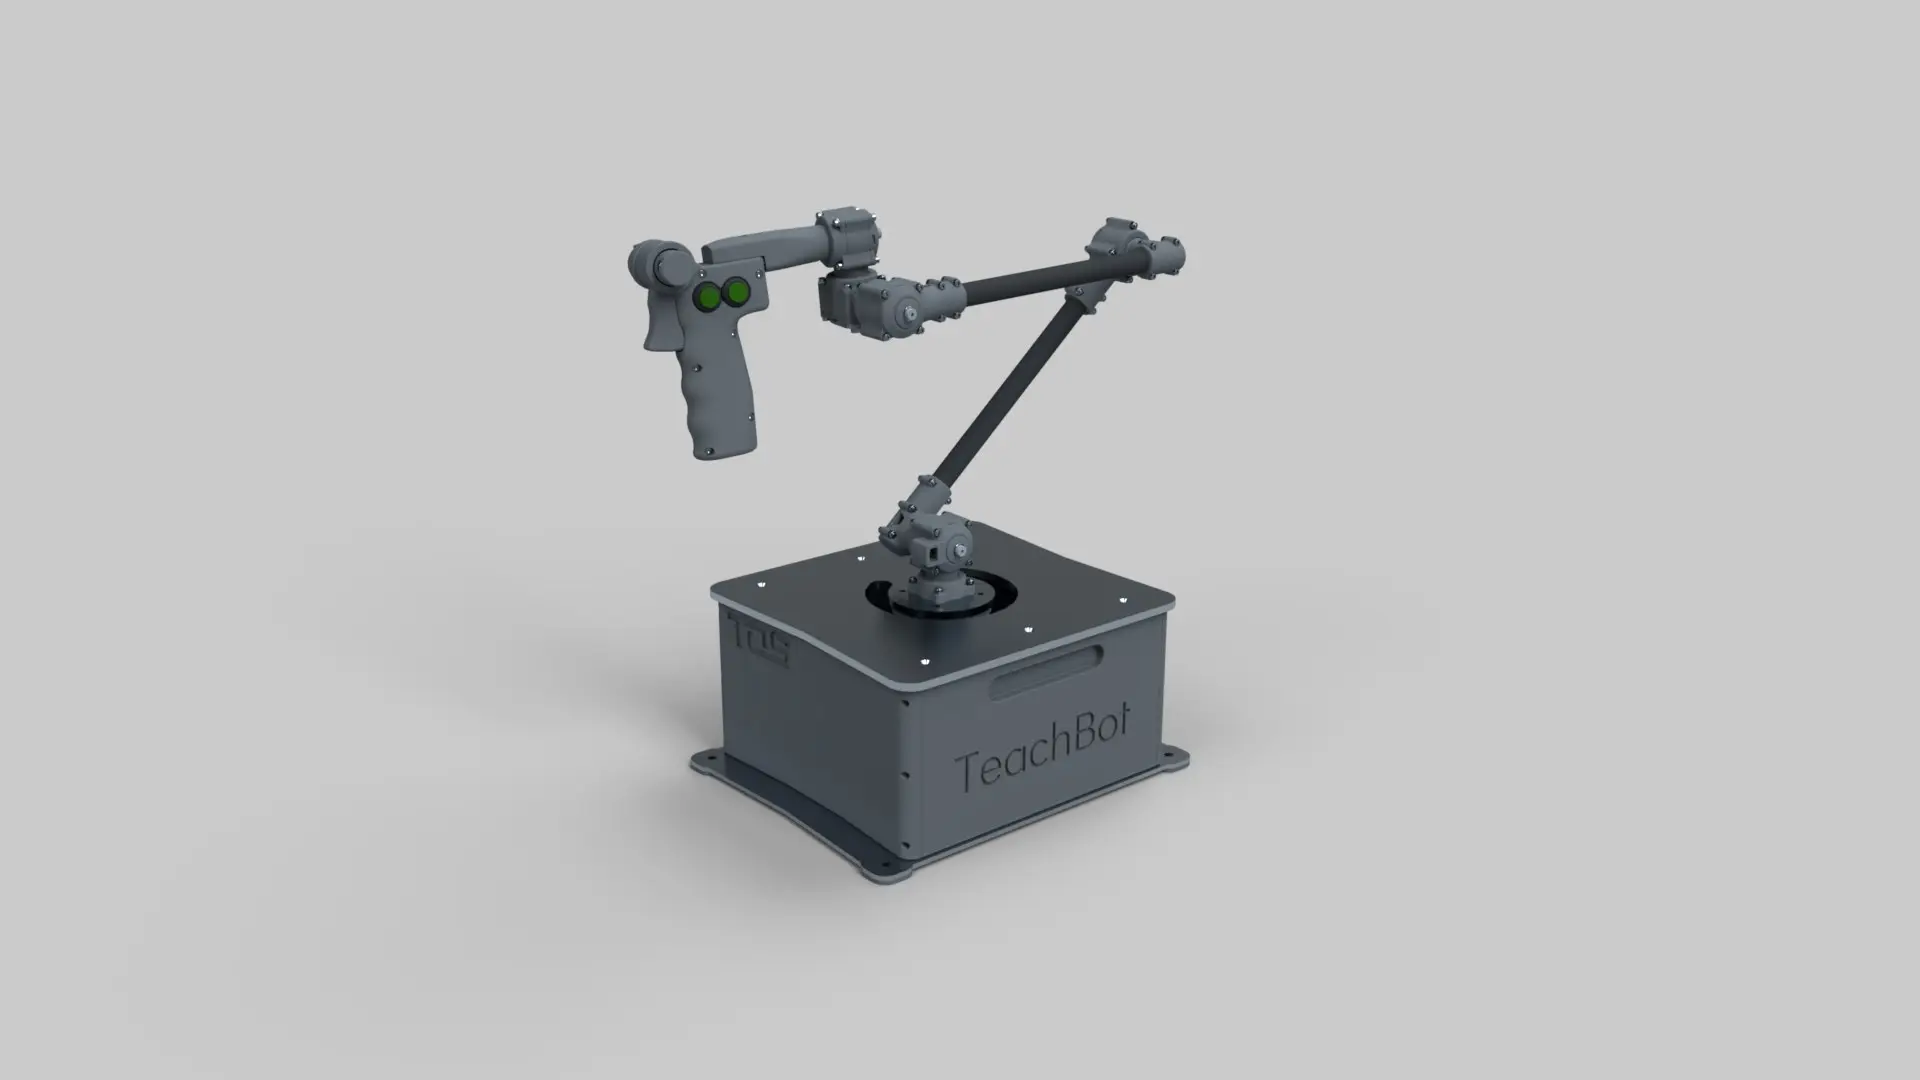
The Teachbot has passive joints of 57 g with 17-bit encoders. See why we built our own Teachbot.
Grippers
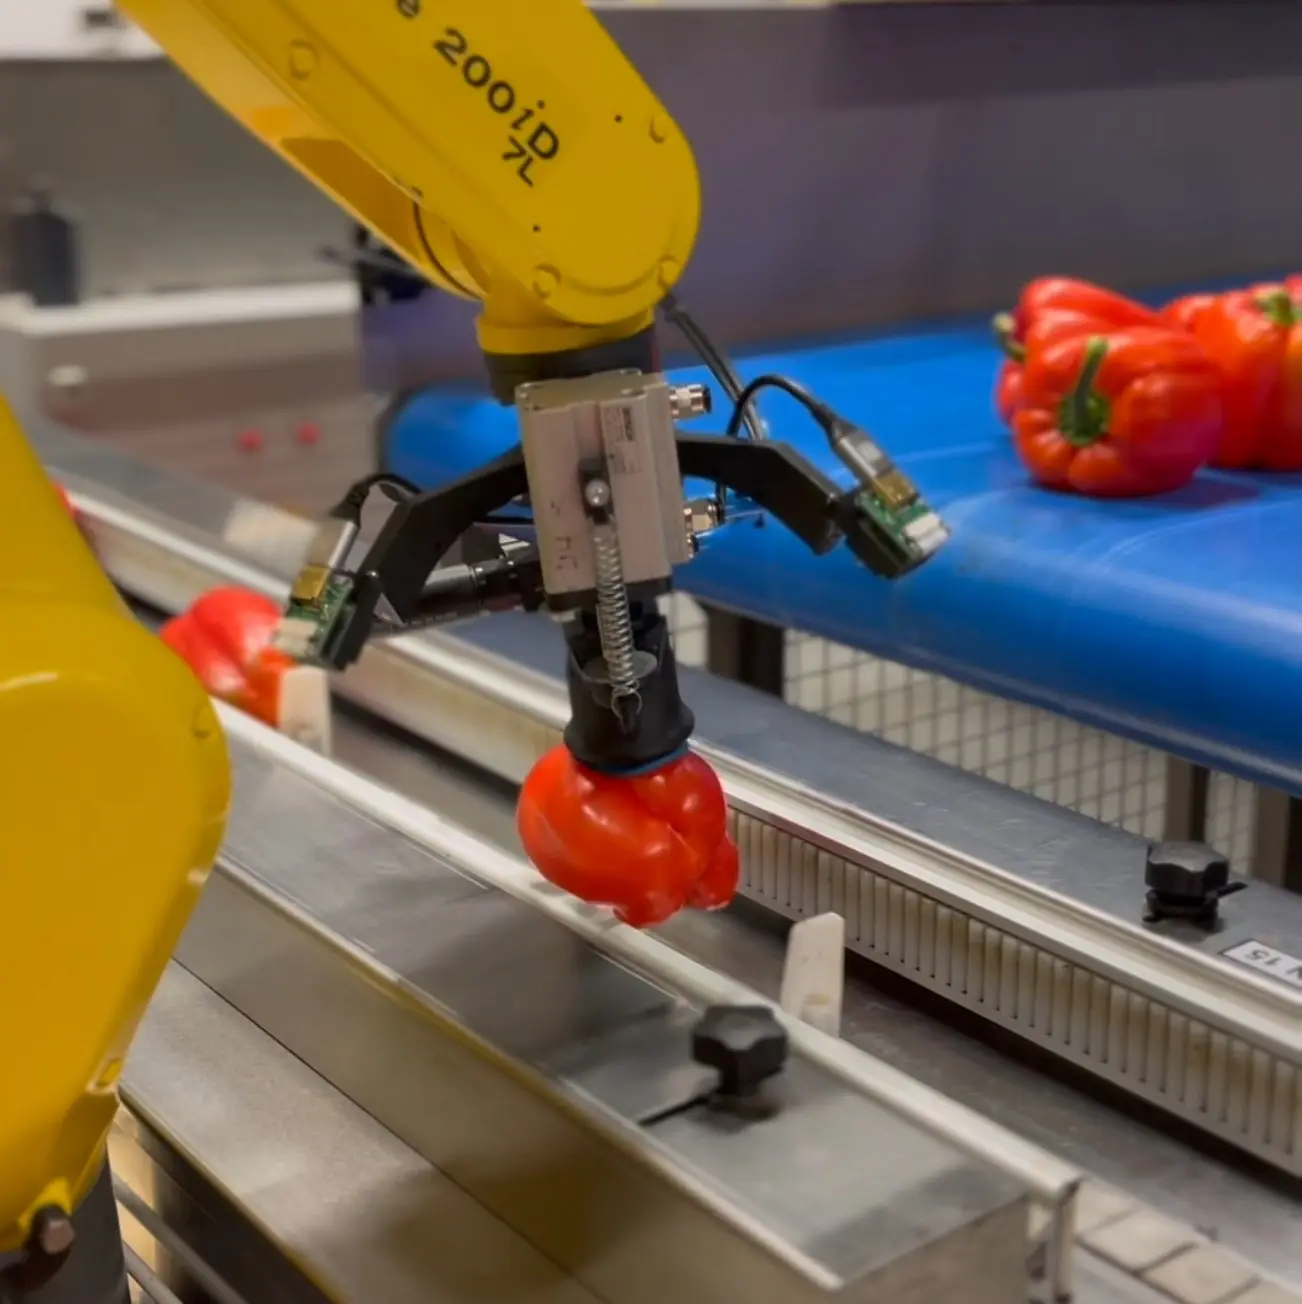
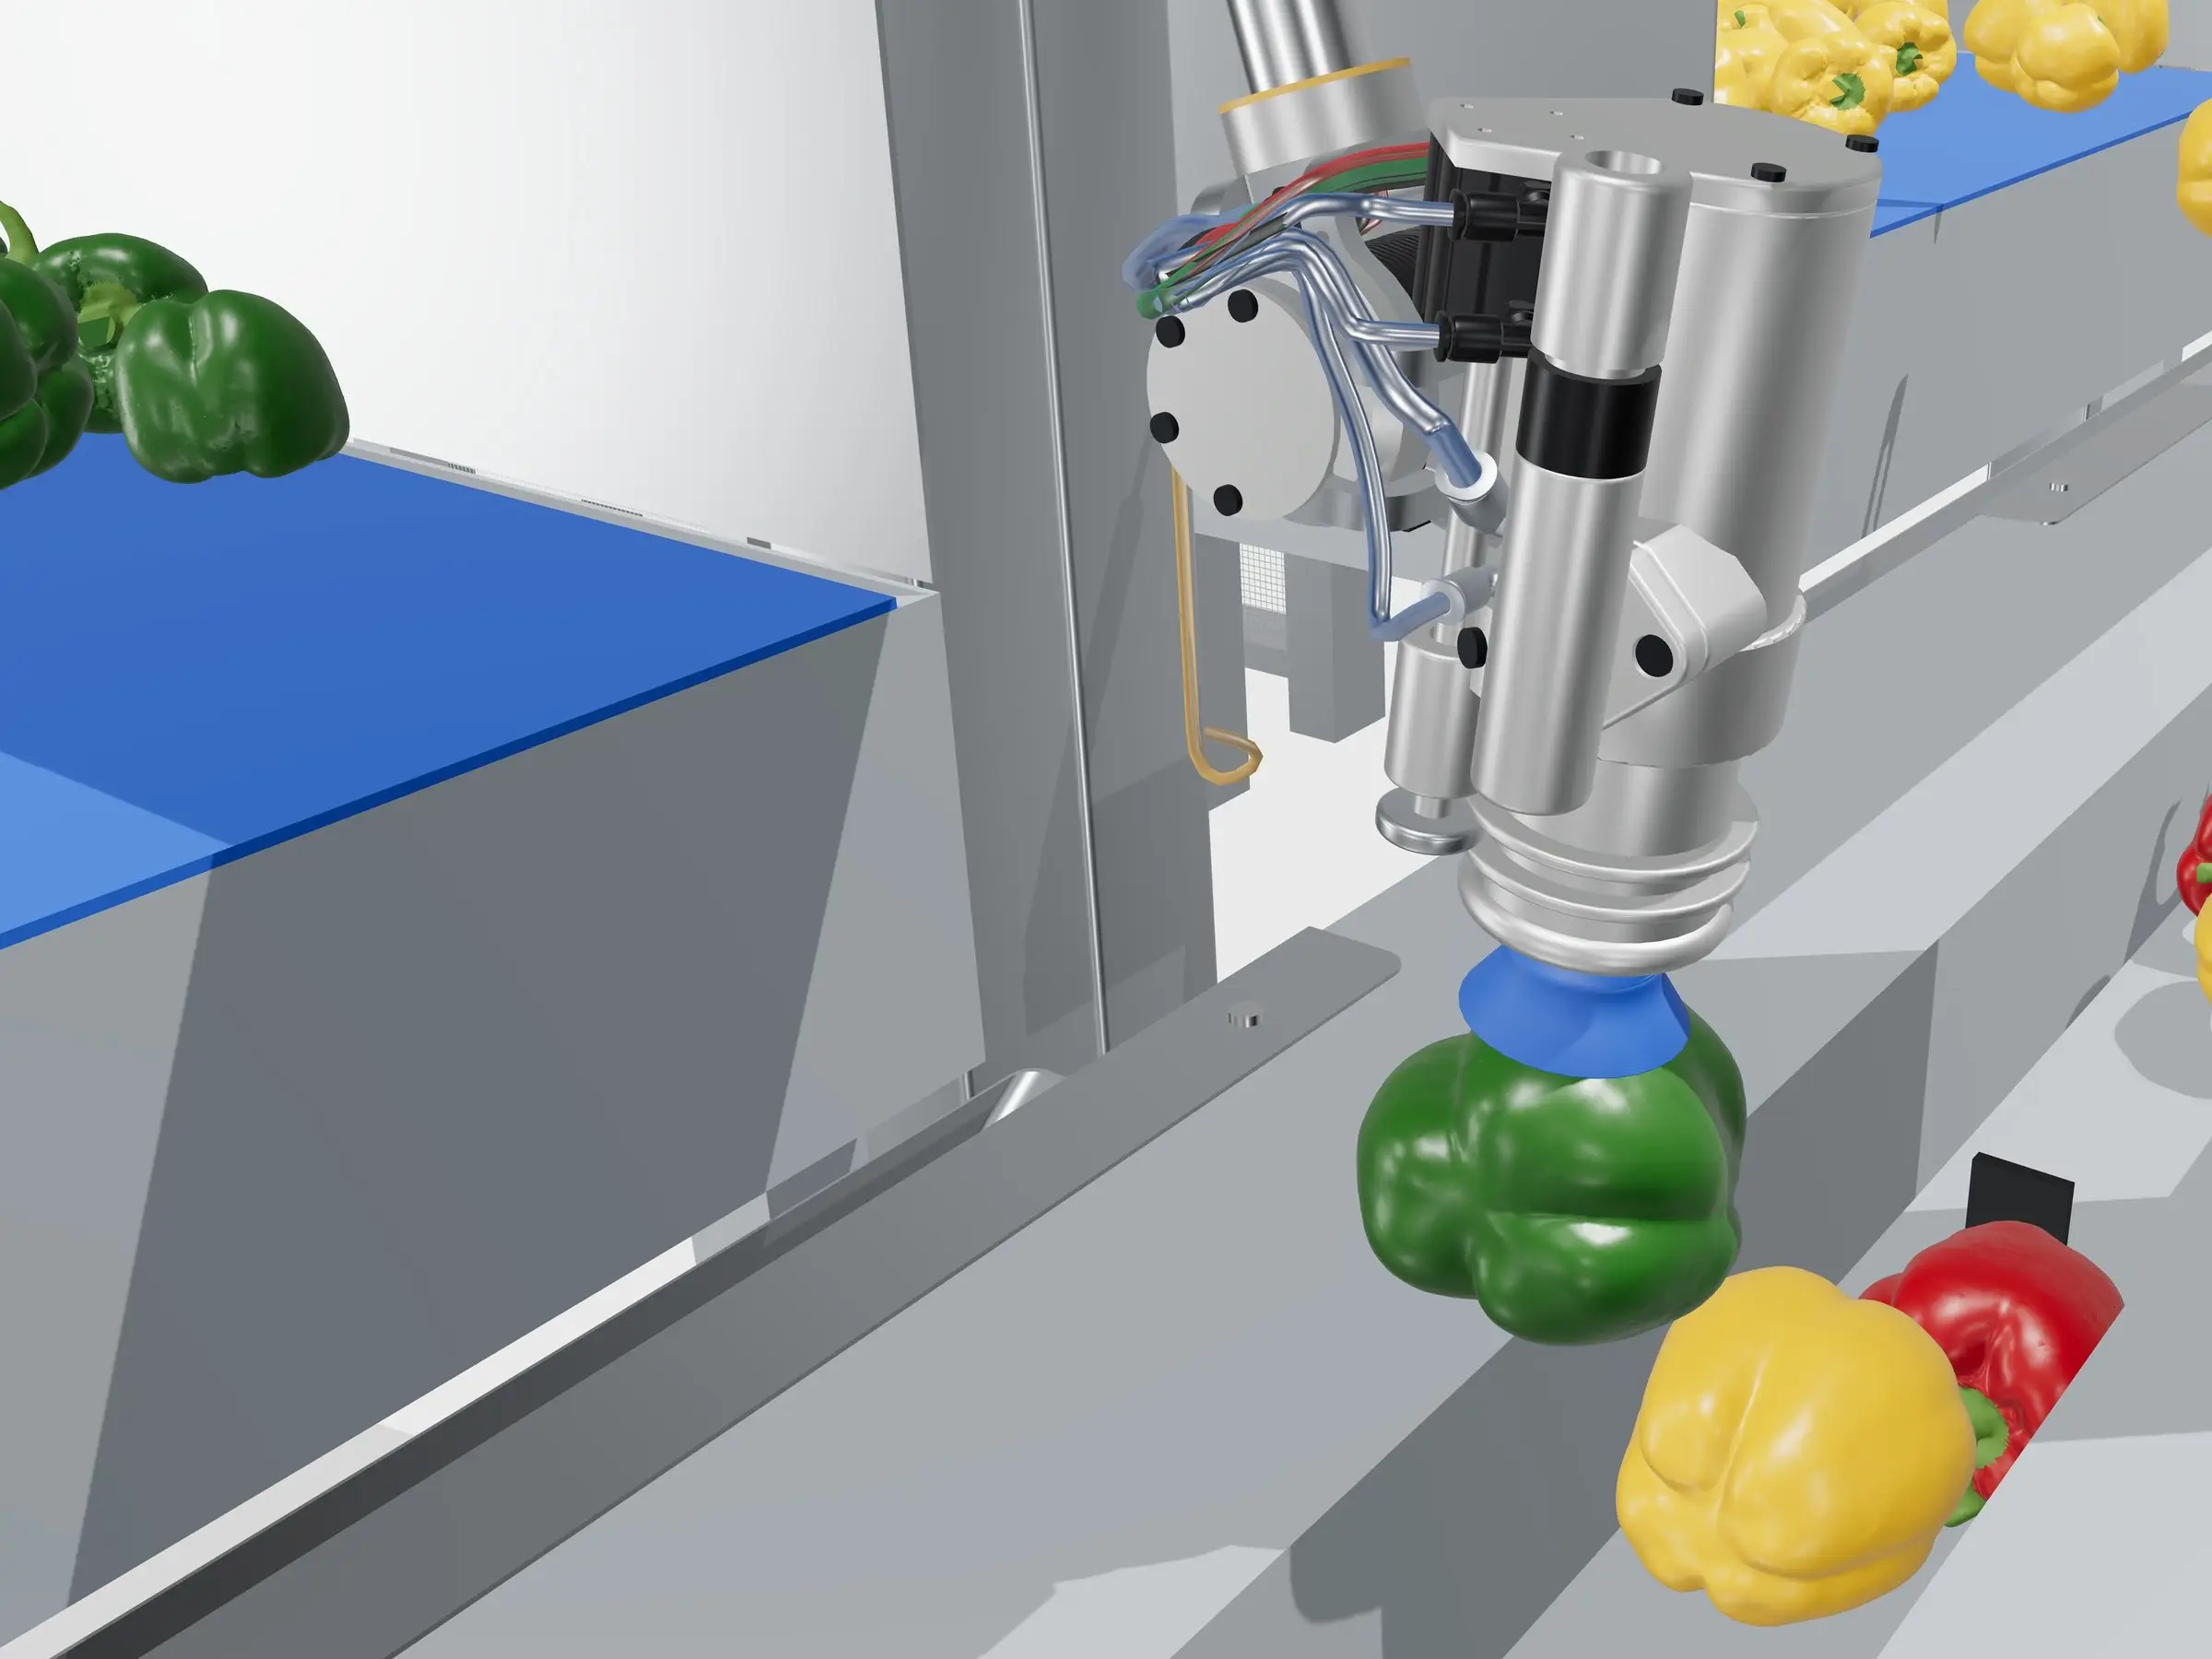
We design the gripper with the cell. On the bell pepper line a suction cup lifts each pepper from the belt.
Complete cells
We design the cell around the line. Encoders and inspection cameras run over Ethernet or a fieldbus, not over USB.
Where it is used
Flowpacking cell
A complete cell that fills the flowpacker. €150,000 per cell. In production.
TOS Robot
Our own robot arm for high-speed picking and placing. Three arms on one beam.
Teachbot
A teaching tool. Guide it by hand and the robot follows. Sold on its own.
Questions and answers
Why does TOS Robotics design its own hardware?
Because the parts of a cell follow from its task. Our first teaching arm was too coarse for fine corrections by hand, so we built the Teachbot. Industrial arms are made for heavy loads, so we designed the TOS Robot for the light load of fresh produce.
Why do you keep USB out of the cell?
Because a USB device can stop without a clear error. Why we keep USB out of our robot cells has what we measured.
Do you design cells for food other than fresh produce?
Yes. Cells for cream on cakes and meal packages are ready for deployment.