Robot control: motion, path planning and safety
Robot control is the part of a TOS Robotics cell that moves the arm. The AI model gives a pick pose and a place pose. Robot control gets the arm there on a moving belt, within its limits and on time. We drive FANUC arms in production and our own TOS Robot.
- In production
- FANUC controller with line tracking
- Streaming
- A joint target every 4 ms
- Planner
- Jerk-limited, our own
- Safety
- Certified hardware, apart from the AI
A robot controller picks its own timing for every corner. Where that is not good enough, our planner takes over.
What we build
Line tracking
On the bell pepper line the FANUC controller tracks the belt itself. Our cells pick while the belt moves.
Path planning
Our planner limits speed, acceleration and jerk. Offline it needed less time than the FANUC planner for the same moves. It is not yet used on a production robot.
Motion streaming
Every 4 ms our PC gives the robot its next joint position, so we set the timing and the limits. We use it for cream on cakes, where a taught pattern keeps its own timing on a moving belt.
Limits and stops
Our streaming planner for the cream line stays below the limits of the controller, and any alarm is a stop with the motor power off. Poses that the joint limits or safety zones would block are filtered out of the training data.
Measured on real cycles
We judge each change on the logged position of the robot, every 4 ms, over tens of thousands of cycles.
Where it is used
Flowpacking cell
A complete cell that fills the flowpacker. €150,000 per cell. In production.
TOS Robot
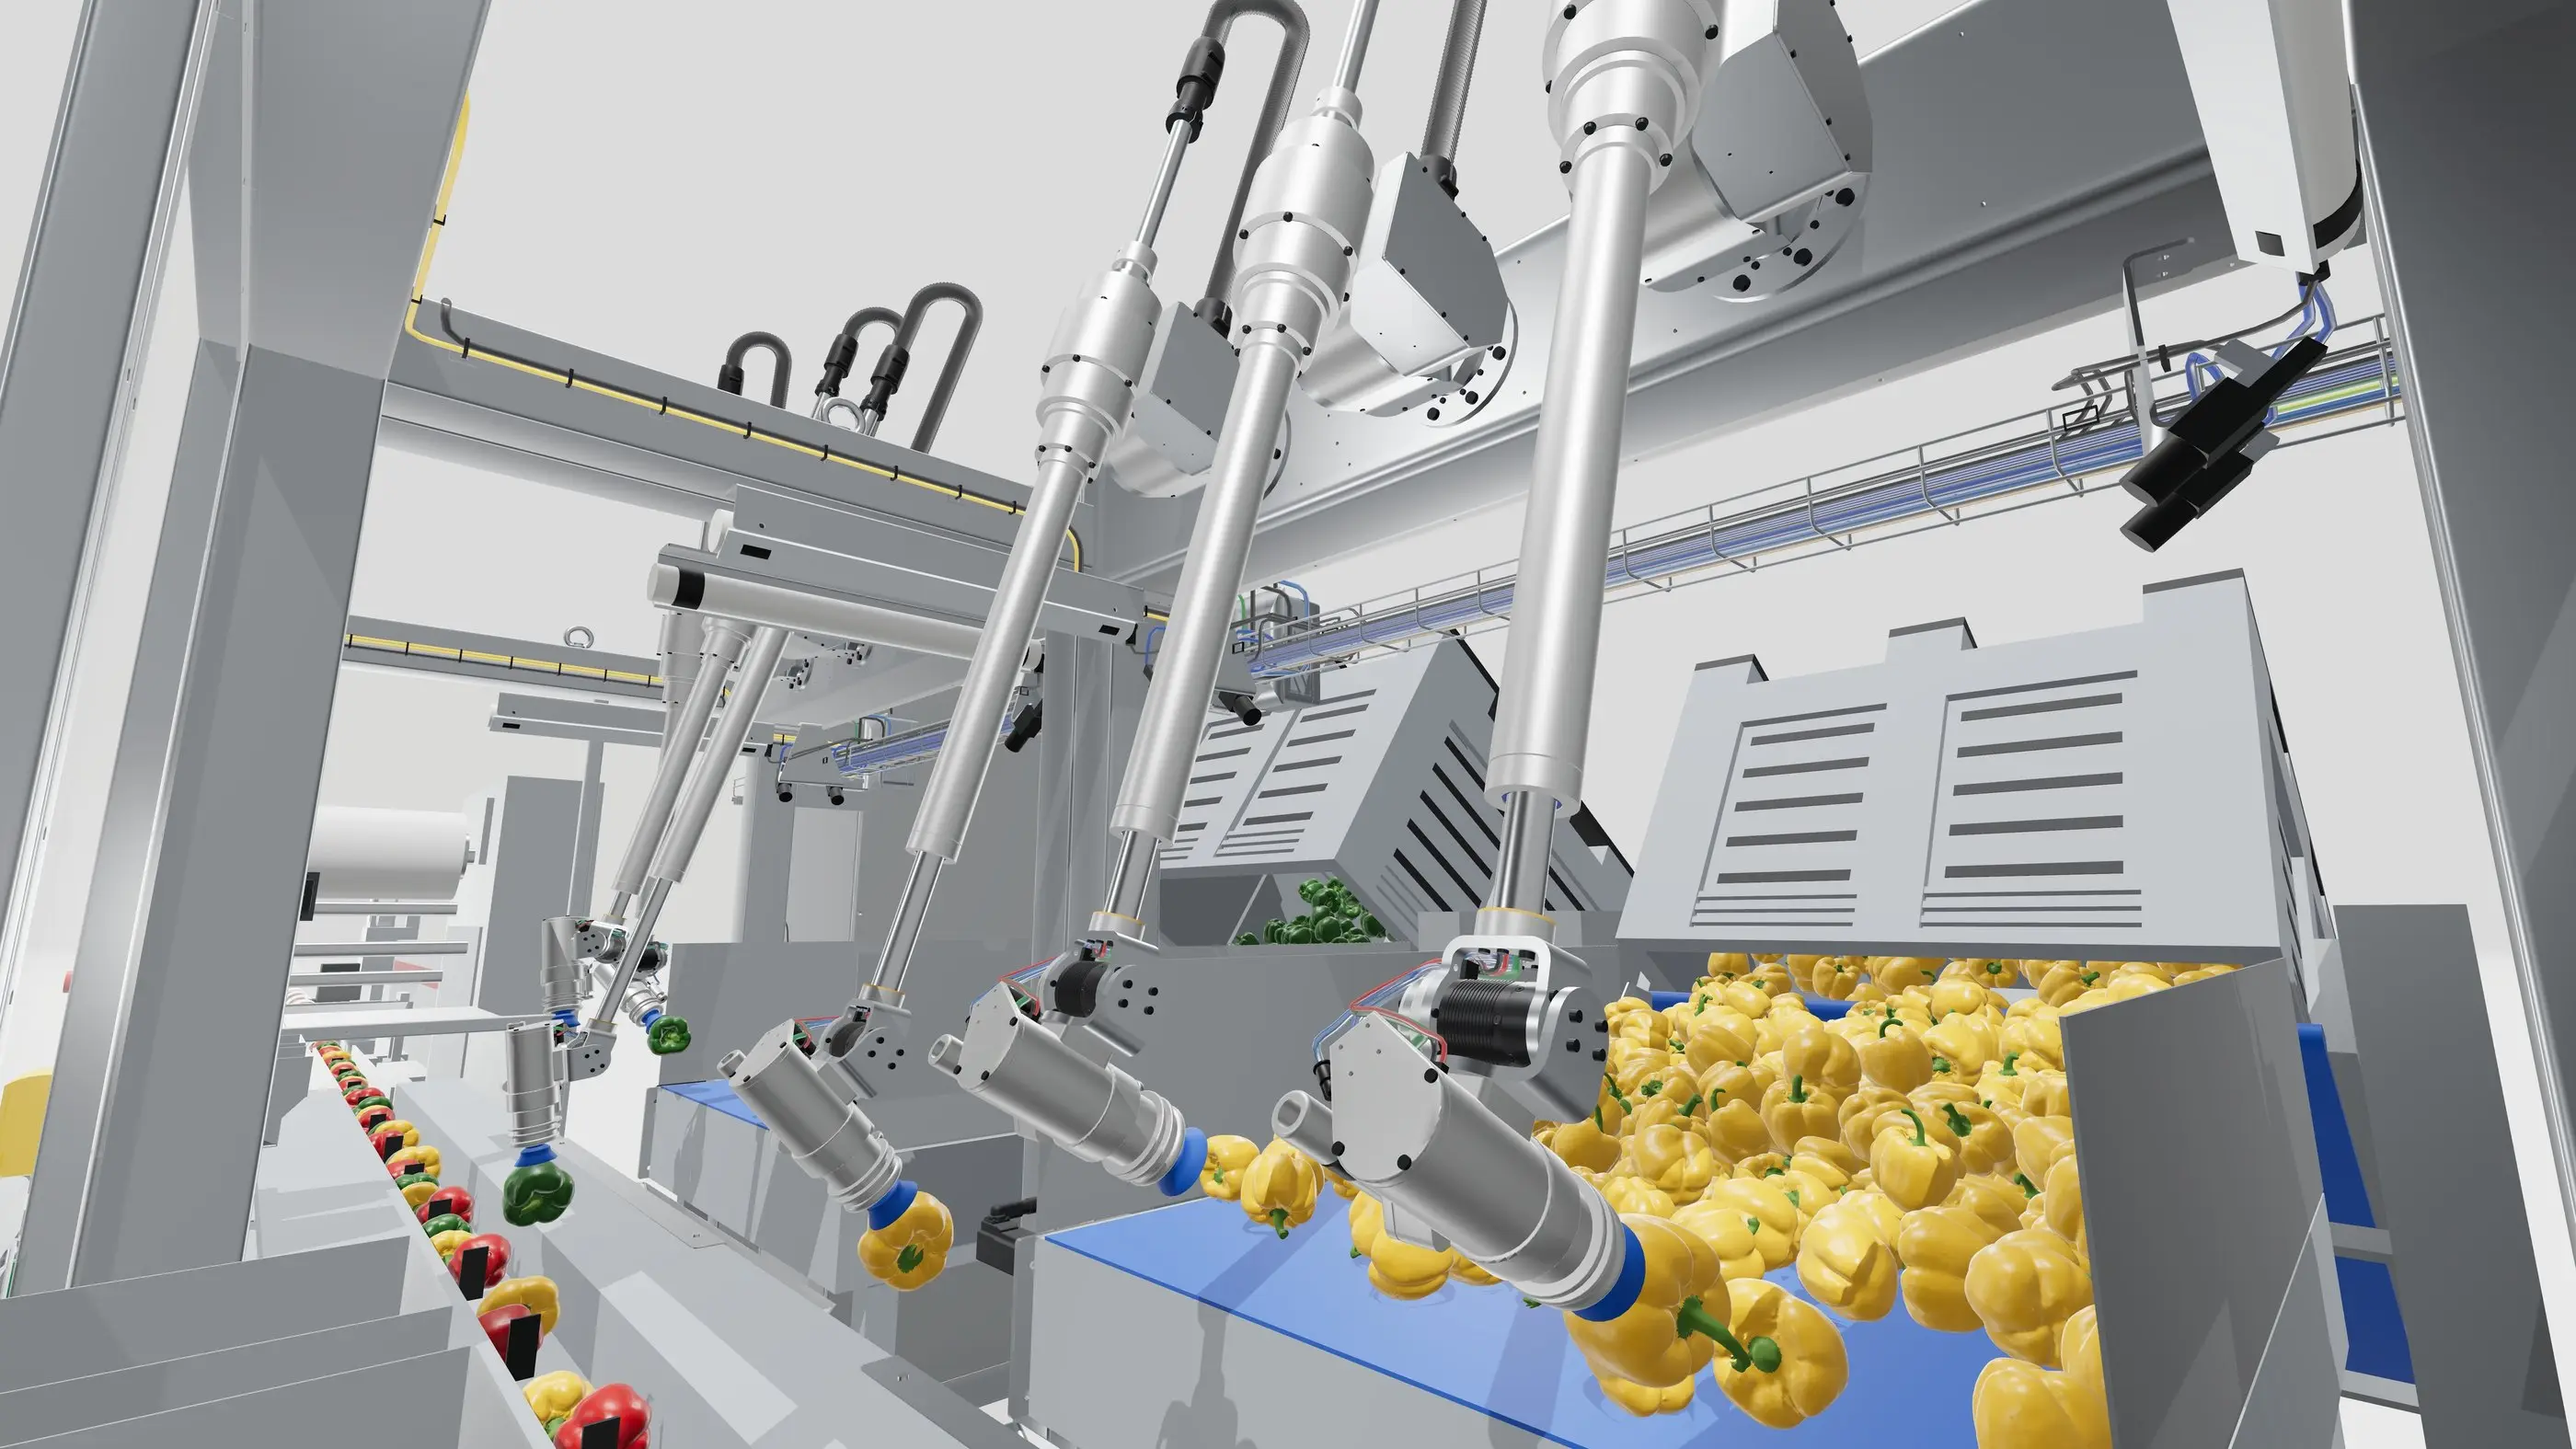
Our own robot arm for high-speed picking and placing. Three arms on one beam.
AI robot control software
The software that runs a robot cell. Licence for robots of any brand.
Questions and answers
Which robots does TOS Robotics control?
FANUC arms on the bell pepper line, and the TOS Robot, which uses our own planner from the start.
Does the belt have to stop for a pick?
No. Every TOS Robotics cell tracks the belt, so the robot picks while the belt moves or stands still. This is called line tracking.
Why not let the robot controller plan the whole path?
Because the controller rounds a corner differently at another speed. On our robots the same corner was cut by 14 mm when the arm started from rest and by 24 mm when it arrived moving. Why a taught robot path cannot simply be sped up has what we measured.
Is the robot safe next to people?
A TOS Robotics cell is a guarded industrial cell. The AI decides where to pick and place. The safety of the cell is handled by certified safety hardware, separate from the AI.
Keep reading
- Why a taught robot path cannot simply be sped upRaise the speed and a blended corner moves. On our robots the same CNT50 corner cut 14 mm from a standstill and 24 mm from a moving start.
- How do you make ACT move a robot arm smoothly?ACT took 17.1 ms per prediction on average on our robot and 97.9 ms at worst. The chunk handover is sized for the slow case.